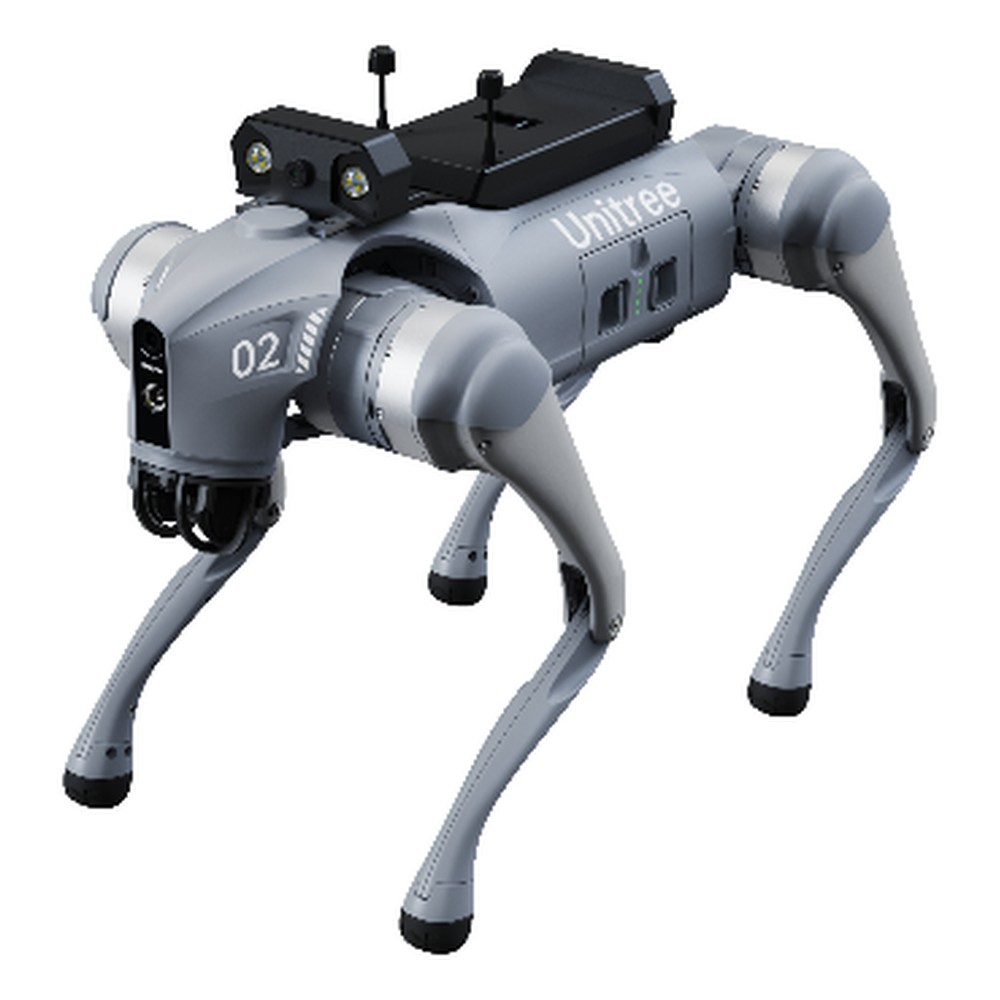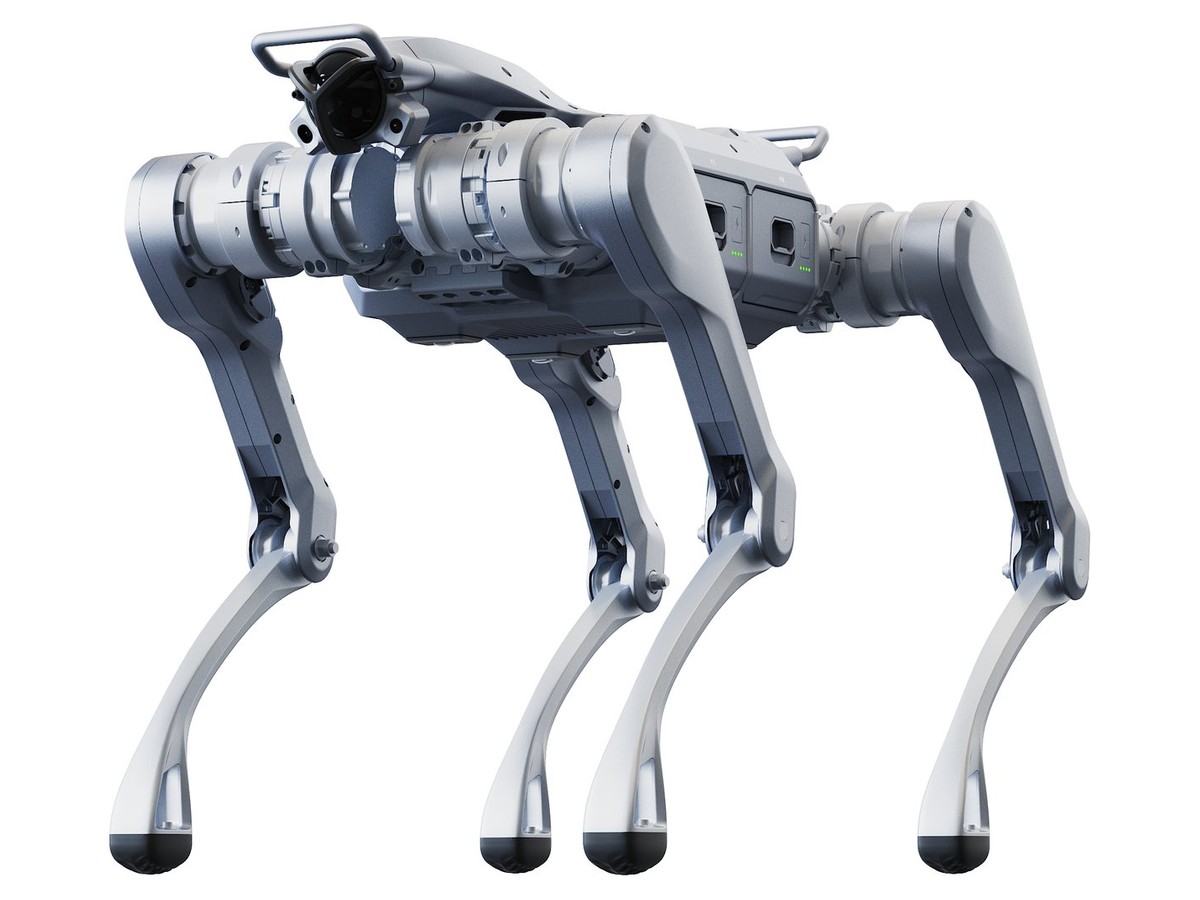
If you are weighing a quadruped for a specific task, the details decide whether it pays off.
This guide covers “trigger alarms from on-device detection” on the Unitree A2. It assumes you have the robot, a development machine and the official SDK.
What you need
- A Unitree A2 with a charged battery and a safe open area for testing.
- SDK 2.0 installed (C++/Python) and a ROS 2 workspace if you use it.
- A host machine on the same network as the robot.
- The Unitree account and the robot’s serial for licence-linked features.
Step by step
- Update firmware and confirm the robot reports healthy telemetry.
- Connect from the SDK and read a live state sample to prove the link.
- Implement the smallest version of “trigger alarms from on-device detection” you can, and log every run.
- Add safety limits: speed caps, geofence and an e-stop path.
- Test on flat ground, then one harder surface, before any real deployment.
- Document the routine so the next operator can repeat it.
Common pitfalls
- Skipping the flat-ground test and going straight to hard terrain.
- Forgetting spare batteries for long autonomous schedules.
- Writing custom gait code before the stock stack is understood.
- No e-stop or geofence — never skip the safety path.
Next steps
Once the basics work, move the behaviour into simulation (NVIDIA Isaac) to tune it safely, then deploy to the real Unitree A2 with logging turned on.
Frequently asked questions
Do I need ROS 2 for this?
No. The Python SDK is enough for most tasks; ROS 2 helps when you already run a robotics stack.
Can I run it without writing code?
Yes for patrol and mapping via the app; custom “trigger alarms from on-device detection” needs the SDK.
Want the hardware to try this on? Unitree A2 Request a quote remote-control a robot dog over 4G/5G: a step-by-step guide for the Unitree B2 build an autonomous patrol route: a step-by-step guide for the Unitree G1 How to set up the Unitree SDK 2.0 on a Unitree Unitree G1.
Specifications are publicly reported and approximate; exact figures depend on configuration, region and production batch. Confirm the current sheet with your supplier before purchase.